Robot Gearbox Housings and Transmission Components

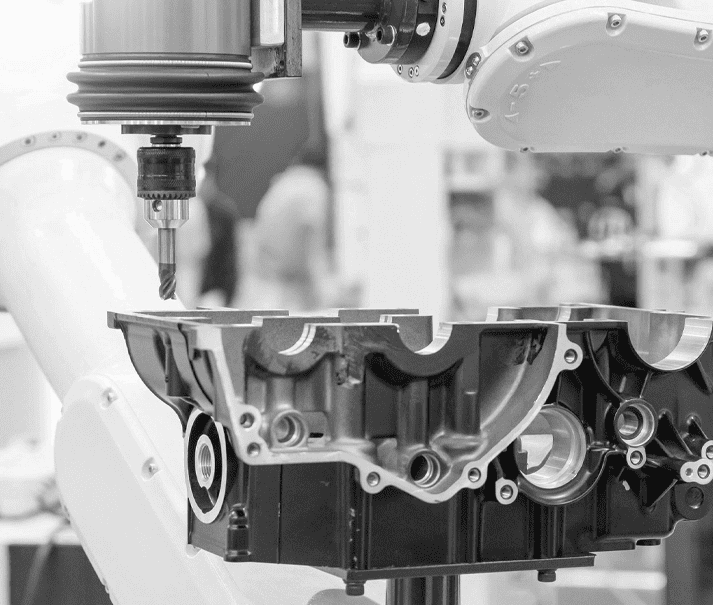
We machine robot gearbox housings, carriers and shafts to your drawing for robot OEMs and joint module developers.

Robot Gearbox Housings and Transmission Components Featured Image
Overview

Robot Gearbox Parts, Machined to Drawing

Bearing bores, carrier pin positions and shaft journals keep the gear stage aligned. We do not sell finished gearboxes: we machine transmission components to your drawing.

  • Bearing bore fits per ISO 286, as bearing makers advise
  • Input and output bores machined in one setup
  • Matched sets when the drawing requires it
  • From prototypes to pilot and low-volume repeat production
Request A Quote
Product Intro Image
What we machine

Robot gearbox components we machine

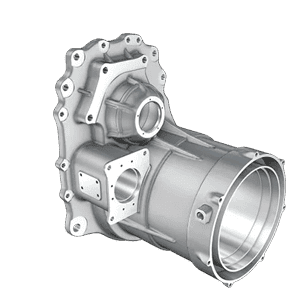
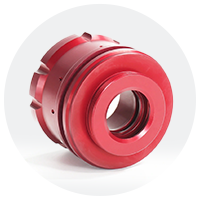
  • Planetary housing
  • RV reducer parts
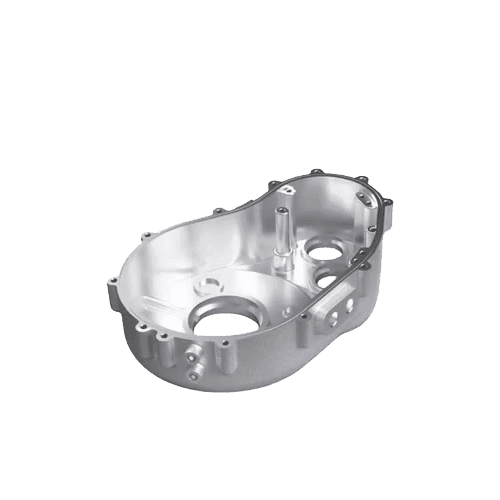
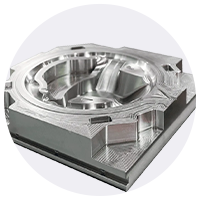
  • Harmonic housing
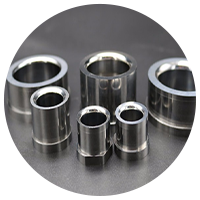
  • Bearing seats
  • Gear shafts
  • Planetary gear housings
  • RV reducer components
  • Harmonic drive housings
  • Bearing seats
  • Gear shafts
  • Planetary gear housings

    Ring-gear seats concentric to the output bearing, with input and output bores machined in one setup, for planetary gearbox stages in legged robots and wheels.

  • RV reducer components

    Pin housings, carriers and crankshafts for RV reducers in heavy-load arm joints; compare RV and harmonic reducers.

  • Harmonic drive housings

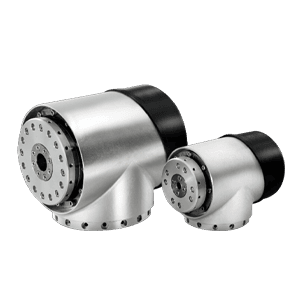
    Thin-walled housings around the strain wave stage of compact humanoid and cobot joints, with circular spline bodies and their mounting features.

  • Bearing seats

    Bearing housings and seats with controlled fits and shoulders, bored to the fit the bearing maker recommends for bearing life and gear-stage stiffness.

  • Gear shafts

    Input, output and precision shafts with journals ground after heat treatment, plus couplings between the motor and the gearbox input.

Tech Specs

Technical Specifications

Product Specs Image
Material 7075-T6, 6061-T6 aluminum; 42CrMo; 20CrMnTi, 8620; 17-4PH
Process CNC milling and turning; precision grinding; EDM slots
Heat treatment Carburized or induction hardened, per the route on your drawing
Surface finish Hard anodizing on aluminum; electroless nickel, black oxide
Tolerances Fits per ISO 286; GD&T to ASME Y14.5 or ISO 1101
Inspection Against the GD&T callouts of your drawing
Quantities Prototypes, engineering builds, pilot and low-volume repeats
Application Robot joints, actuators, reducers and AMR drive units
Highlights

Design points for a machined robot gearbox

  • Coaxial bores Featured Image

    Coaxial bores

    Input and output bores held coaxial to ASME Y14.5 or ISO 1101 so the gear stage runs true.

  • Carrier pin positions Featured Image

    Carrier pin positions

    Planet-pin holes positioned from the carrier axis, with parallelism held so every planet shares the load.

  • Matched sets Featured Image

    Matched sets

    A housing and its cover, or a carrier pair, machined as a matched set when the drawing requires it.

  • Engineering review Featured Image

    Engineering review

    An engineer reviews bore fits, pin positions and the heat-treatment route before quoting.

Engineering

Critical tolerances in gearbox housings, carriers and shafts

FeatureWhy it mattersHow it is specified
Bearing boresBearing life and gear-stage stiffnessFit per ISO 286, as the bearing maker recommends
Coaxiality of input and output boresThe gear stage runs trueCoaxiality or runout to ASME Y14.5 or ISO 1101
Center distanceMesh and backlash of parallel-shaft stagesPosition tolerance between bores
Planet-pin hole position on carriersLoad sharing between planetsPosition from the carrier axis
Mating facesClamping without distortionFlatness and squareness
ShaftsBearing preload and runoutJournal fits, runout
Composition

Component Material & Finish

FAQs

Robot gearbox FAQs

Send CAD and drawings; an engineer reviews manufacturability before quoting. NDA available on request.

What types of gears are used in robotics?
Strain wave (harmonic), cycloidal or RV, planetary, and parallel-shaft spur or helical stages. The choice trades backlash, stiffness, size and cost.
Do you sell complete robot gearboxes?
No. We machine gearbox housings and transmission components to your drawing: housings, carriers, shafts, bearing seats, couplings and flanges.
Do you make gears?
Spur and helical gears can be machined to your drawing on request, to the accuracy grade specified on that drawing. Our focus is the housings and transmission parts around the gear stage.
Which steel do you recommend for gearbox shafts and carriers?
42CrMo for through-hardened shafts and carriers; carburizing steels such as 20CrMnTi or 8620 where a hard case is needed on pins and journals.
Can you machine prototypes of a new reducer design?
Yes, with no minimum quantity for prototypes, then engineering builds, pilot and low-volume repeat batches.
How do you check bearing bores and carrier pin positions?
Against the GD&T callouts of your drawing.