


-
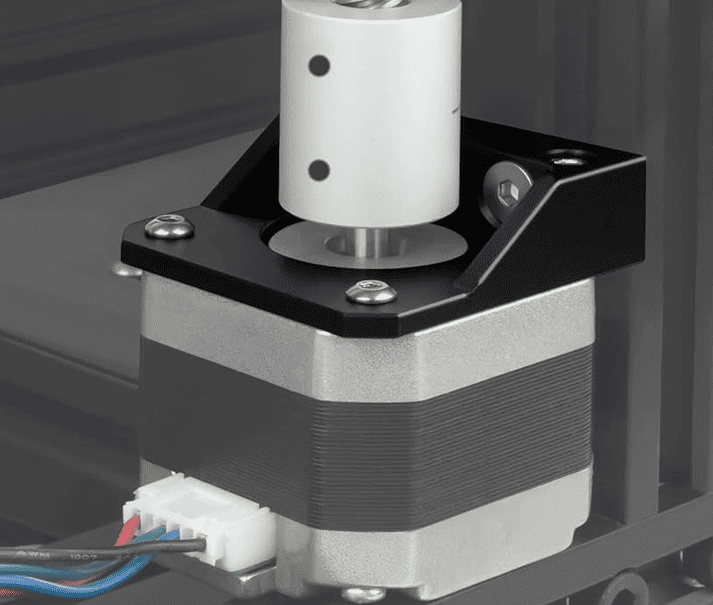
Mount and gearbox adapter
The motor pilot on one face and the gearbox input on the other, coaxial in one part, machined to the same datums as the robot gearbox components.
-
Mount and bearing seat
The motor face and a bearing seat for the output shaft are machined in one setup, so the motor and the driven shaft are located in a single part.
-
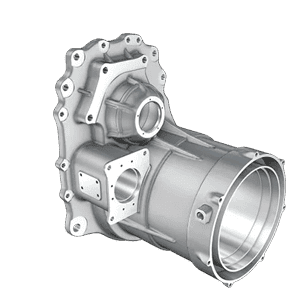
Mount and coupling housing
A bell housing that carries the motor on one end and encloses the motor coupling between motor and load, with the pilot and mounting face held to your drawing.
-
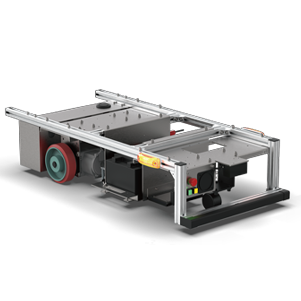
Drive-unit motor mounts
Motor mounts for the drive units of wheeled robots, machined together with the other AGV and AMR parts of the same robot.
-
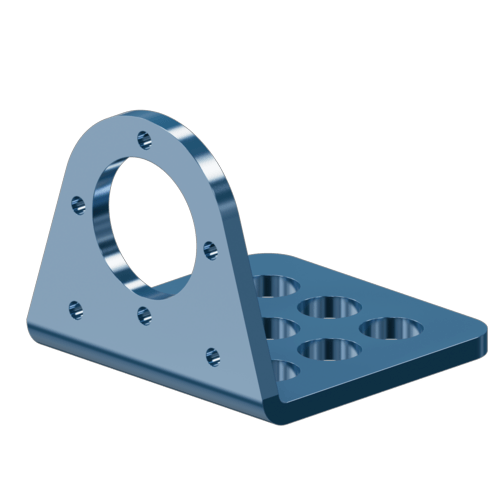
Adapter plates
Plates for fitting a different motor to an existing interface, with the pilot bore, bolt circle and face of the new motor located to the existing mounting points.

Custom Servo Motor Mount Machining for Robots
We machine each custom servo motor mount to your drawing for humanoid, quadruped and AMR robot programs.